
 Browse Code

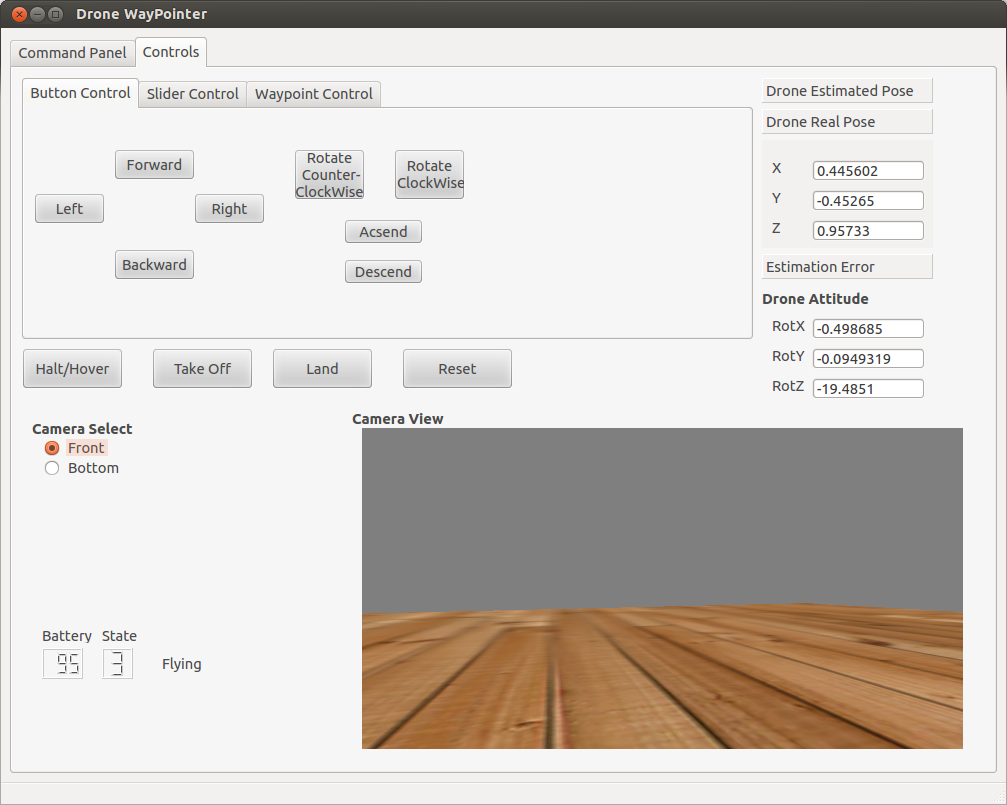
"Drone WayPointer" is a ROS package that provides a UI to allow for remote control of the Parrot AR Drone 2.0. It is developed in C++ with qt-ros and the Qt4 Development FrameWork. It is designed to work with the ROS - Fuerte and it uses the the ardrone_autonomy driver (Fuerte-devel Branch). It has so far only been tested on the tum_simulator and not on the actual drone. The main functionalities it provides is camera streams of front or bottom cameras of the drone, button and slider control of the drone XYZ velocities, control using waypoints and waypoint commands, pose estimation using simple dead-reckoning and measurement and image recording functionalities.
Project Samples




License
GNU General Public License version 3.0 (GPLv3)Follow Drone WayPointer
Other Useful Business Software
Build Data Resilience - Take the Assessment Today
Is your recovery strategy as strong as you think? Take this quick self-assessment to check your recovery readiness and gain tailored insights. In only 2 minutes, you'll learn where you fall on the recovery readiness scale.
Rate This Project
Login To Rate This Project
User Reviews
Be the first to post a review of Drone WayPointer!
