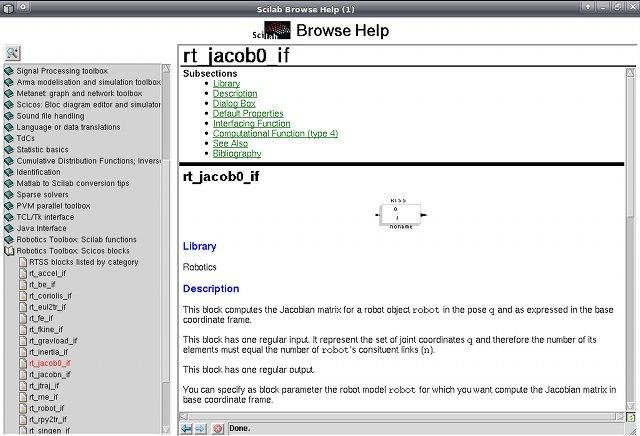
RTSS is intended for modeling and simulation of robotic manipulators in the Scilab/Scicos environment. Inspired by the Robotics Toolbox for MATLAB by Peter Corke, RTSS provides many functions that are useful in the field of robotics.

Project Samples

Project Activity

See All Activity >

License

GNU General Public License version 2.0 (GPLv2)

Follow the Robotics Toolbox for Scilab/Scicos

the Robotics Toolbox for Scilab/Scicos Web Site

Other Useful Business Software
Veeam Data Platform v13.1 - Get Your Free Trial Icon
Veeam Data Platform v13.1 - Get Your Free Trial

Secure by design, portable by default. Recover clean, fast, anywhere. Start a free trial.

Try Veeam Data Platform today. Experience the unified platform that's secure by design, portable by default, and proven to recover clean, fast, and anywhere.
Try it Free
Rate This Project
Login To Rate This Project

User Reviews

Be the first to post a review of the Robotics Toolbox for Scilab/Scicos!

Additional Project Details

Operating Systems

BSD, Linux, Windows

Languages

English

Intended Audience

Education, Engineering, Science/Research

User Interface

Console/Terminal

Programming Language

C, Scicos, Scilab

Related Categories

C Robotics Software, C Simulation Software, C Data Visualization Software, Scilab Robotics Software, Scilab Simulation Software, Scilab Data Visualization Software, Scicos Robotics Software, Scicos Simulation Software, Scicos Data Visualization Software

Registered

2007-09-28