
 Download

Moved to https://github.com/rdiankov/openrave
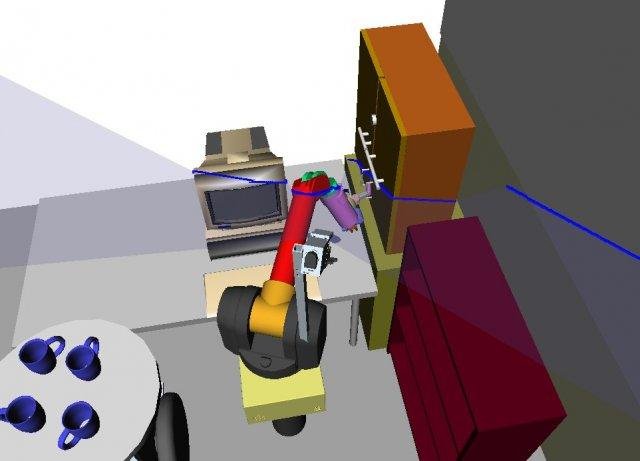
An open-source, cross-platform, plugin-based robot planning environment for autonomous robotics. Includes services like collision detection, physics, (inverse) kinematics, sensors, robot controls, python bindings, and a network scripting environment.
Project Samples


License
Apache License V2.0, GNU Library or Lesser General Public License version 3.0 (LGPLv3)Follow OpenRAVE
Other Useful Business Software
Paessler - Monitor Your Whole Network in Minutes
Waiting weeks for a monitoring rollout isn't an option when infrastructure doesn't stop running. PRTG's auto-discovery scans your network and suggests from over 200 pre-configured sensor types, so you're watching servers, applications and devices within minutes, not after a multi-week deployment. Enterprise-strength monitoring, without the enterprise complexity. Start your free trial today.
Rate This Project
Login To Rate This Project
User Reviews
-
Thank you for your work.
-
Openrave is the best robotics platform ever! It has everything you ever need and is perfect for research development. It comes with plug-ins like bidirectional-rrt based motion planner, analytical inverse kinematics solvers for popular research robots, which are handy and great for getting things started.
